Robot Dexterity
Backed by £88.5m, this programme sits within the Adaptive Machines opportunity space and aims to transform robotic capabilities and unlock a step change in human productivity.
Programme expansion
Since launching in 2024, this programme has supported major developments in robot dexterity hardware – from next-generation actuators and artificial muscles to electronic ‘e-skins’ for enhanced touch. This work has revealed the market demand for complete, field-ready systems that bring these components together. To reflect this ambition, the programme has received additional funding and is now backed by £88.5m, with the expansion focused on accelerating the deployment of operational systems into real-world environments.
Our goal
This programme aims to release the bottlenecks in robotic dexterity and create vastly more capable and useful machines.
Breakthroughs in AI are transforming robotic abilities, but the development of robot bodies has not kept pace with advances in computation. Robots cannot achieve the flexibility, speed, and precision of human manipulation, rendering them useless for many of the difficult or dangerous tasks where we need them most.
The need to improve robot dexterity comes at a critical time. The proportion of the world’s population aged 65+ is expected to triple by 2100, while labour deficits for physically demanding work are set to increase. Robots have the potential to ease these labour shortages and boost prosperity but to do so, we must close the gap between what robots and humans can handle.
We’re funding an array of cutting-edge research across robot hardware and advanced simulation, with the ambition to usher in a new era of dexterity.
Technical areas
This programme is split into three Technical Areas (TAs), each with its own distinct objective:
Novel Hardware
Focuses on innovative components and new approaches to designing and building hardware to enable dexterity.
Socioeconomic Considerations
Focuses on exploring the socioeconomic considerations of increased automation enabled by robot dexterity.
Modularity, Interoperability, Common Standards
Focuses on facilitating modularity, interoperability, and some common standards within robotics.
Robot Dexterity Benchmarks, standards and interoperability for dexterous robotics: Request for Proposal
Robot Dexterity has already funded Creator teams developing the hardware components for dexterous robots, from next-generation actuators to artificial muscles and e-skins. With expansion funding, the programme aims to help turn these advances into complete, field-ready systems. This will be easier if developers can combine technologies and build on one another’s work.
We are now inviting proposals to develop benchmarks, standards, interfaces, or other shared capabilities that make it easier to develop and deploy dexterous robots. Standards for tactile sense data are a particular priority, alongside wider work on benchmarking, performance evaluation, hardware and software interoperability, and shared testing infrastructure.
Apply by 01 December 2026 (13:00 GMT).
Explore the funded projects
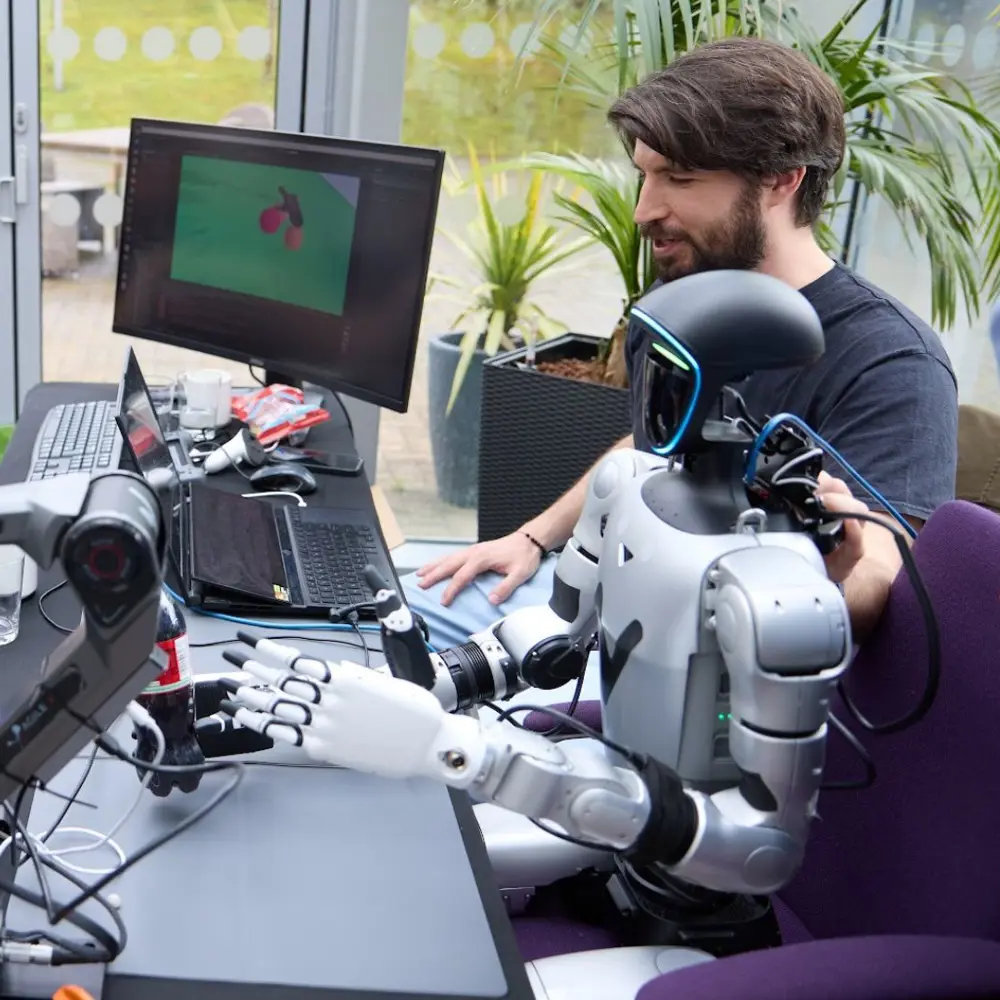
We've selected and funded teams with expertise across multiple disciplines and a strong institutional mix, spanning startups, university labs, public research institutions, and large companies. Together, they'll bridge the software-hardware gap in robotics, realising the full potential of more dexterous robots to advance human productivity and welfare.
Meet the programme team
Our Programme Directors are supported by a core team that provides a blend of operational coordination and highly specialised technical expertise.
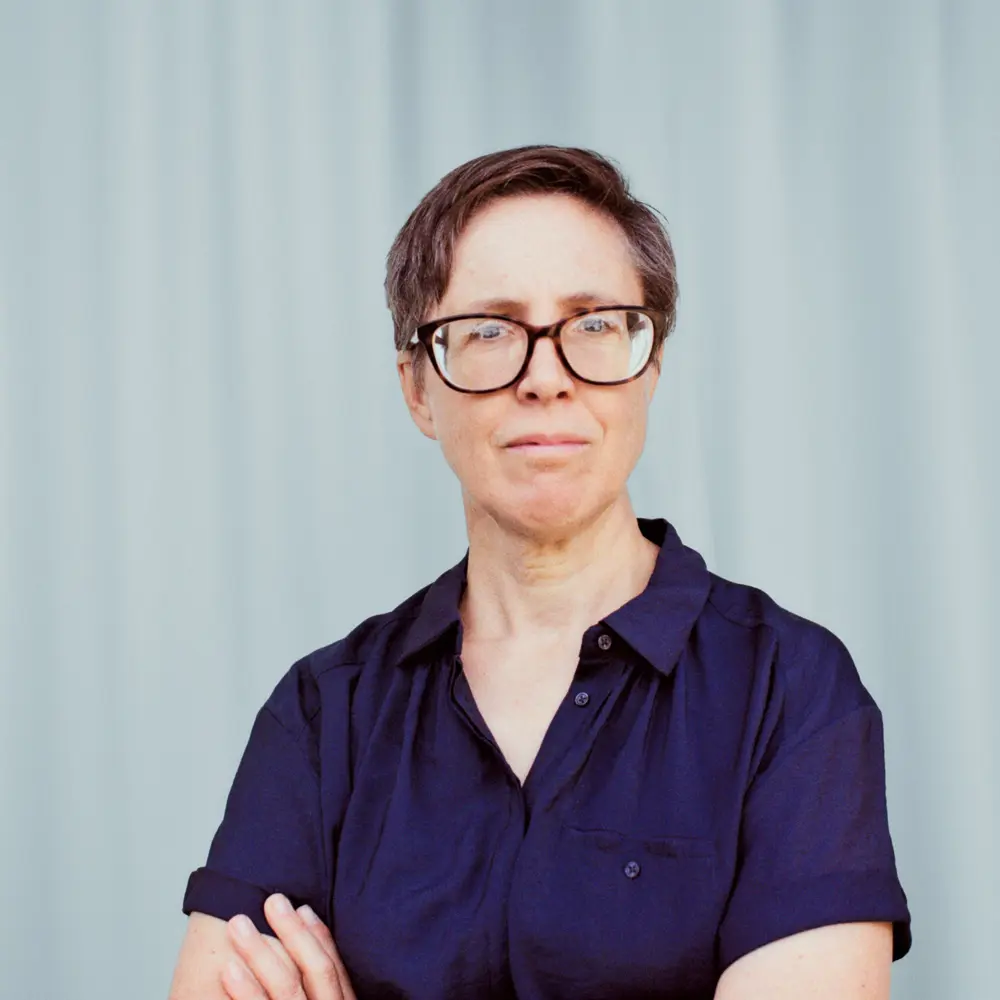
Jenny Read
Programme Director
Originally trained in theoretical astrophysics, Jenny Read spent many years in computational visual neuroscience and joined ARIA from her role as Professor of Vision Science at Newcastle University. Her programmes aim to create the next generation of robot hardware – smarter robot bodies enabled by novel actuation and sensing, and by new approaches to design.
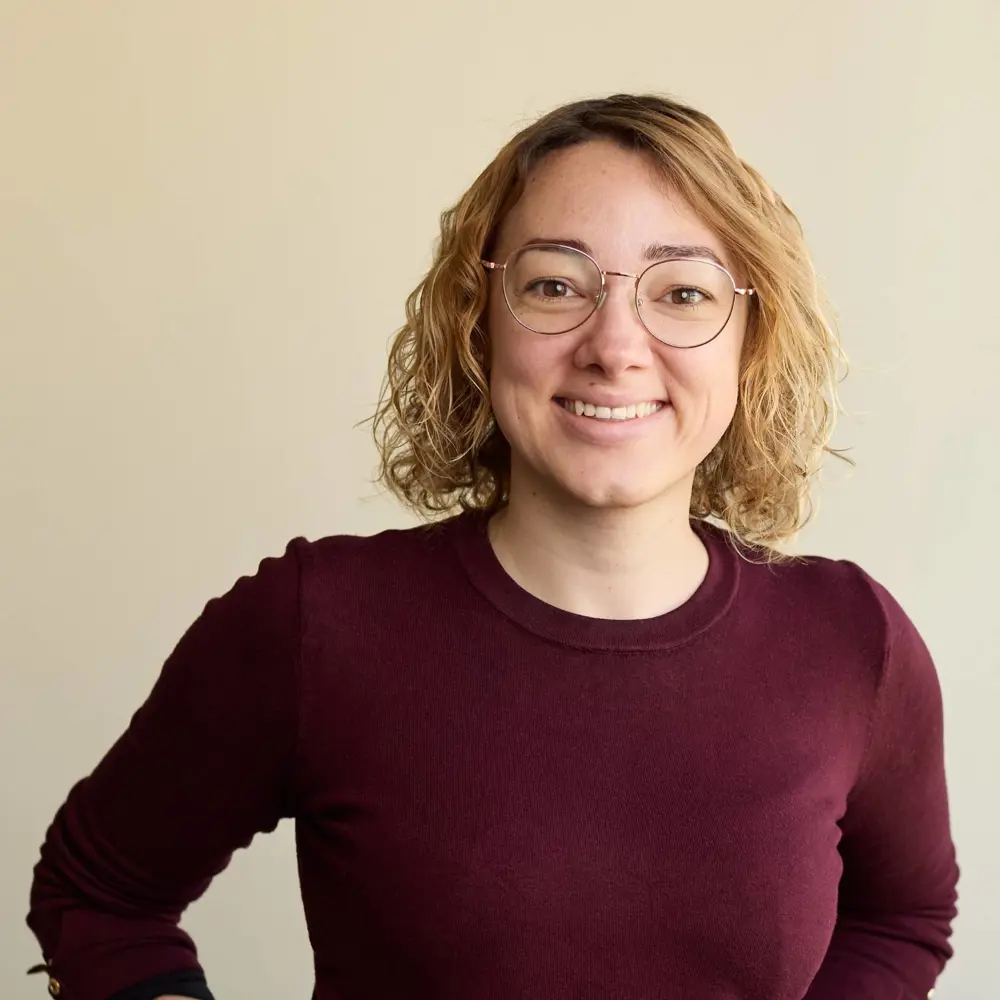
Celia Choimet
Programme Specialist
Celia has an international background in consulting and research management. Before joining ARIA, she spent years in Singapore facilitating the development of international research partnerships between a major French research agency and ASEAN countries, while also coordinating a large-scale Franco-Singaporean initiative focused on Hybrid AI. Celia supports ARIA as an Operating Partner from Pace.
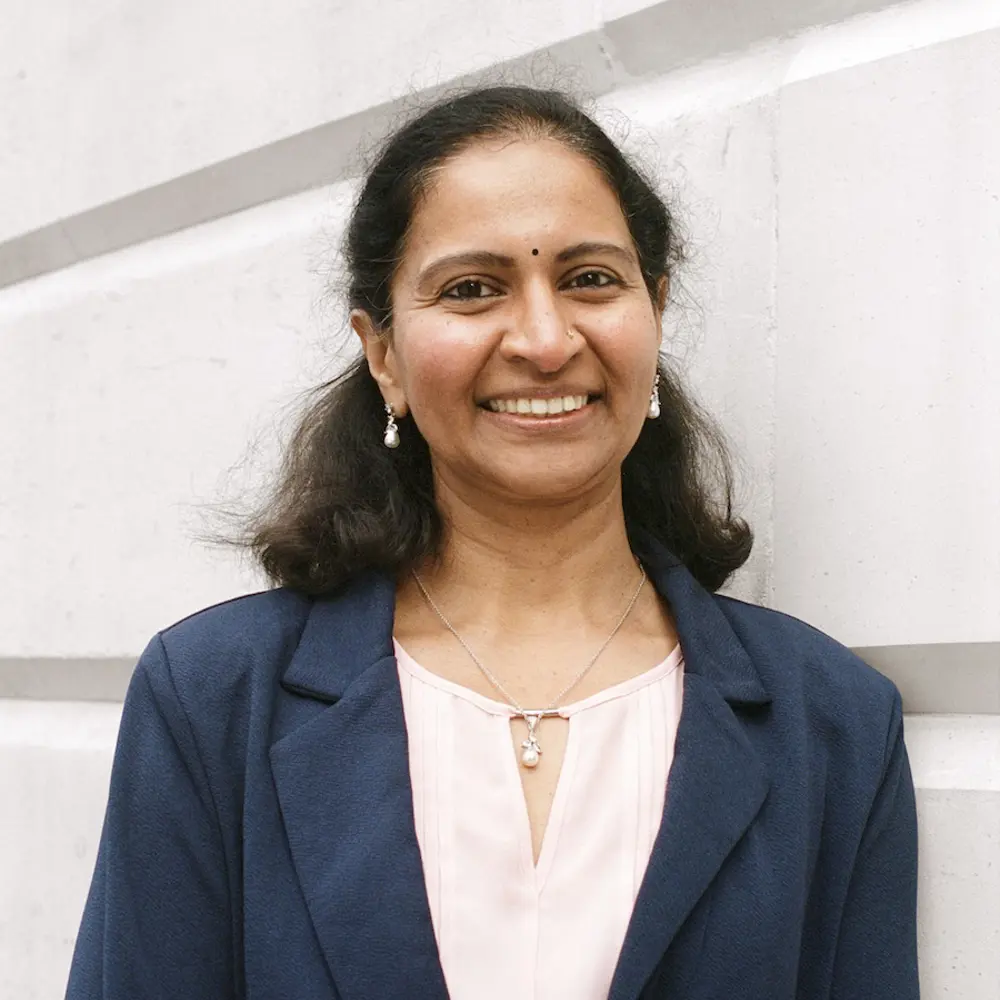
Radhika Gudipati
Science + Technology Lead
Radhika has fifteen years in the robotics industry and is passionate about entrepreneurship, laboratory automation, and sustainability. She works between engineering and user perspectives, drawing from her roles at Ocado Technology and Shadow Robot, where she focused on robotics research and business solutions. Radhika holds a PhD in robotics for healthcare from the University of Hertfordshire.
Featured insights
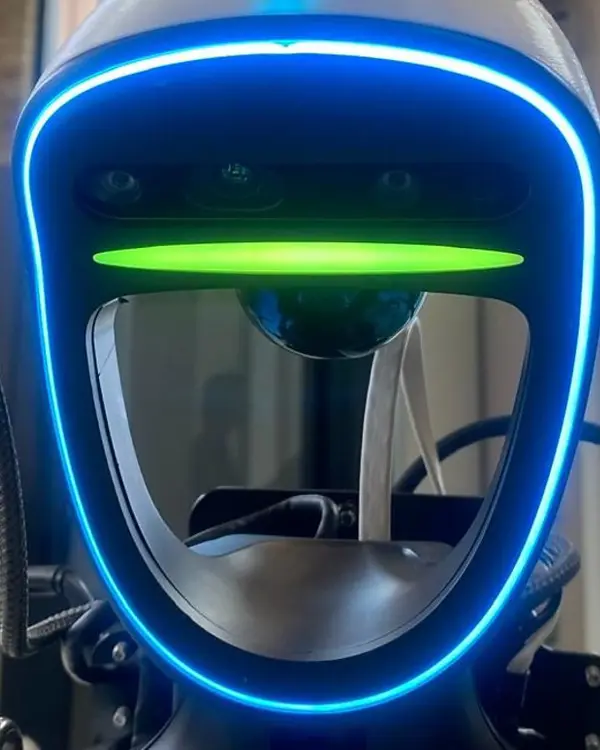
The virtual worlds where robots are trained
BBC News
The robotics firms racing to improve robot training systems.
Sign up for programme updates
Receive the latest updates from this programme, including funding opportunities, programme developments, events, activities and ways to get involved.